Minahil Raza
I am a Doctoral Researcher in the Aalto Robot Learning Group at Aalto University, advised by Prof. Joni Pajarinen. My research focuses on enabling robots to operate robustly in partially observable, dynamic, and unstructured environments. I investigate methods that enable robots to adapt to uncertainty, reason about incomplete information, and interact effectively with complex real-world environments.
Previously, I completed an Erasmus Mundus Joint Master's in Engineering of Data-intensive Intelligent Software Systems (EDISS) at Åbo Akademi University and the University of the Balearic Islands, worked on autonomous load handling for heavy machines at Hiab, and was a research fellow at Nokia Bell Labs.

News
- [Aug 2026] I participated in the Berkeley Method of Entrepreneurship (BMoE) bootcamp at UC Berkeley's Sutardja Center for Entrepreneurship and Technology: a week-long hands-on intensive workshop about startup fundamentals. I learnt so much from the fantastic team of mentors and collaborators.
- [Jul 2026] Our paper "Embodied Active Learning under Limited Annotation and Navigation Budget for Object Detection" was accepted to IROS 2026. Preprint available on arXiv, project page here.
- [May 2026] I attended the Unite! Research School 2026 in Oropa and Turin, Italy, on a Unite! grant, joining researchers and industry representatives across digital transition, energy, and enabling technologies.
- [Jan 2026] I arranged and presented a "Spot the Robot Dog" demo at Shaking up Tech, Aalto's yearly event introducing women and gender minorities to university studies, letting visitors control our robot dog Spot via an Xbox controller or hand tracking.
- [Sep 2025] I attended the PAISS summer school at Inria in Grenoble on a fully-funded scholarship, meeting leading researchers in AI and machine learning from Naver Labs and Meta.
- [Aug 2025] I attended the IWIALS workshop at TU Darmstadt, spanning RL, VLAs, locomotion and manipulation.
- [May 2025] I started my PhD at Aalto University in the Aalto Robot Learning Group, advised by Prof. Joni Pajarinen, focusing on robot manipulation and autonomous excavation.
- [Jul 2024] I attended the Cornell, Maryland, Max Planck Pre-doctoral Research School (CMMRS 2024) at MPI-SWS on a fully-funded scholarship.
- [Apr 2024] I was awarded the Extraordinary Master's Award for the best academic record in my degree at the University of the Balearic Islands.
- [Oct 2023] I successfully defended my thesis, "Whole-body Manipulation using Reinforcement Learning," available here.
- [Oct 2023] Our paper "Environmental stiffness restores mechanical homeostasis in vimentin-depleted cells" was published in Scientific Reports.
- [Jan 2023] Our paper SACPlanner: Real-World Collision Avoidance with a Soft Actor Critic Local Planner and Polar State Representations was accepted to ICRA 2023.
Publications
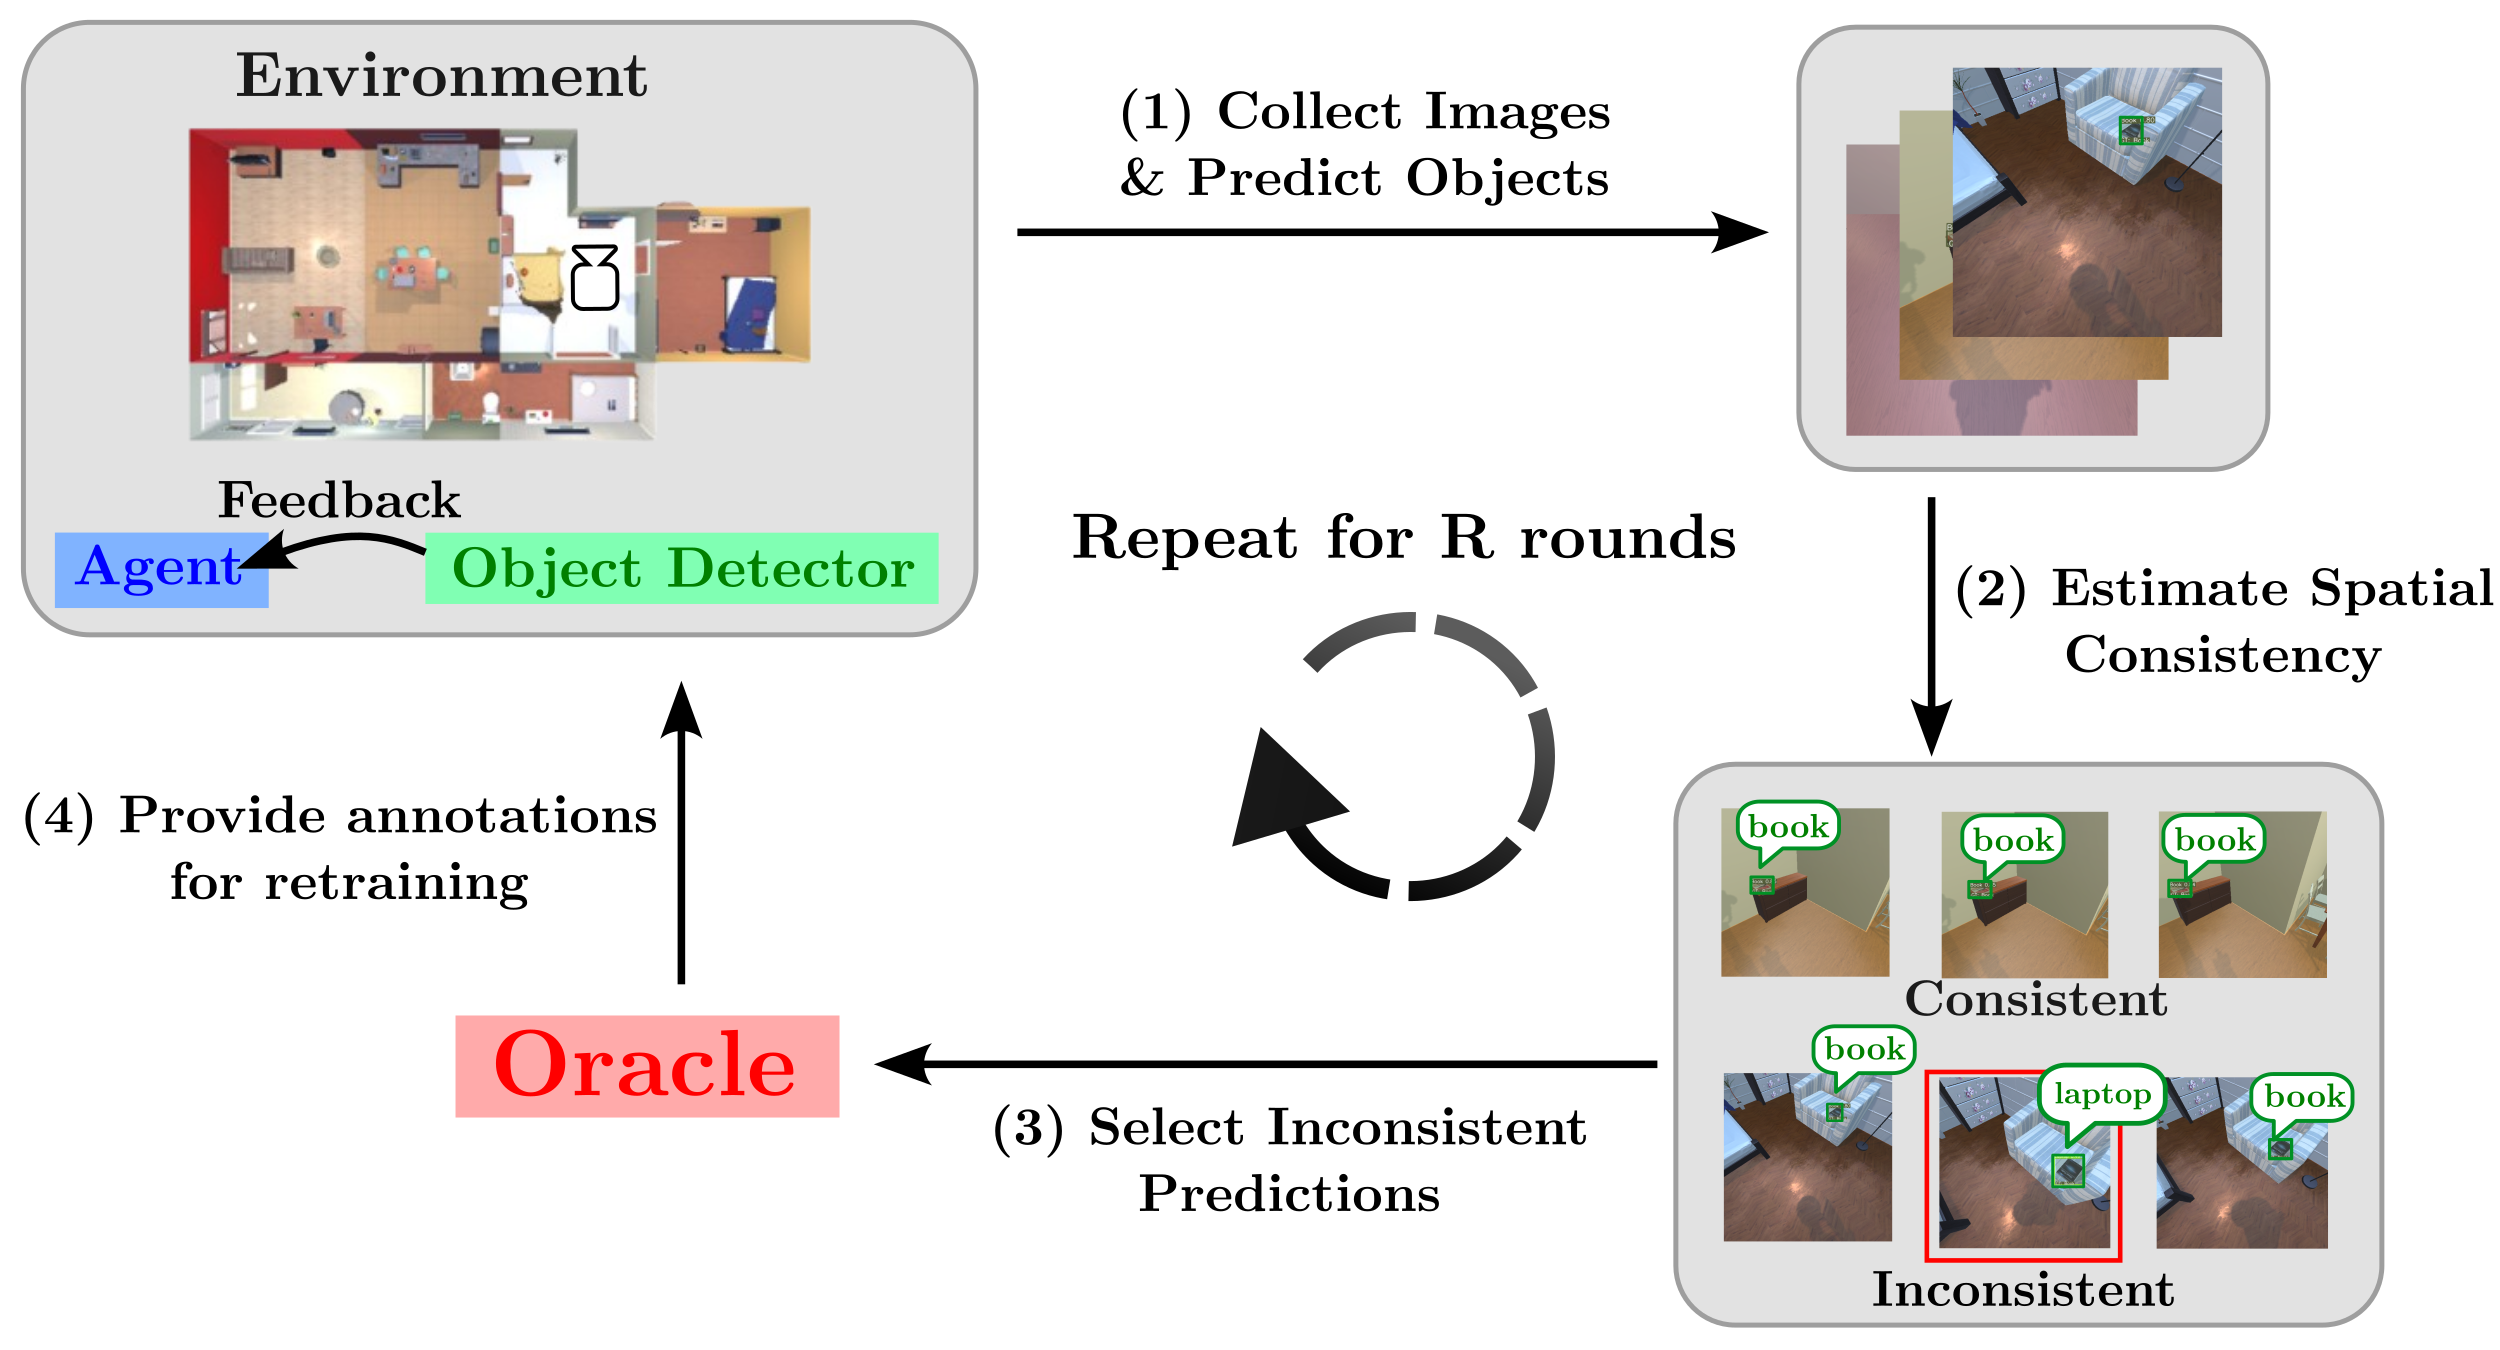
Embodied Active Learning under Limited Annotation and Navigation Budget for Object Detection
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
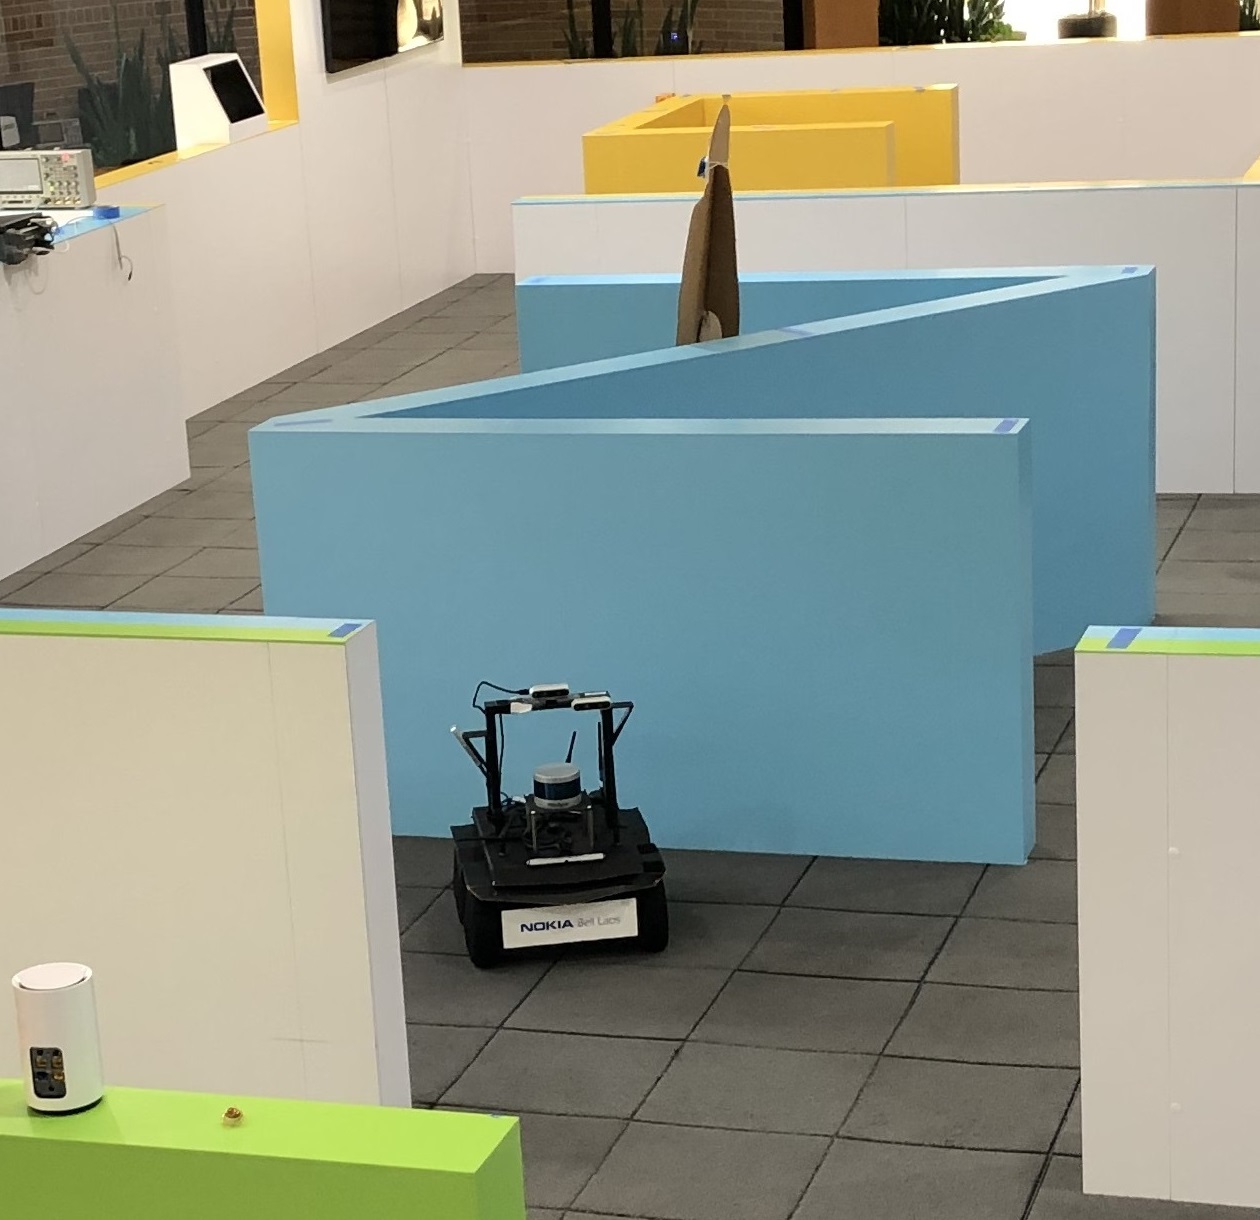
SACPlanner: Real-World Collision Avoidance with a Soft Actor Critic Local Planner and Polar State Representations
IEEE International Conference on Robotics and Automation (ICRA), 2023
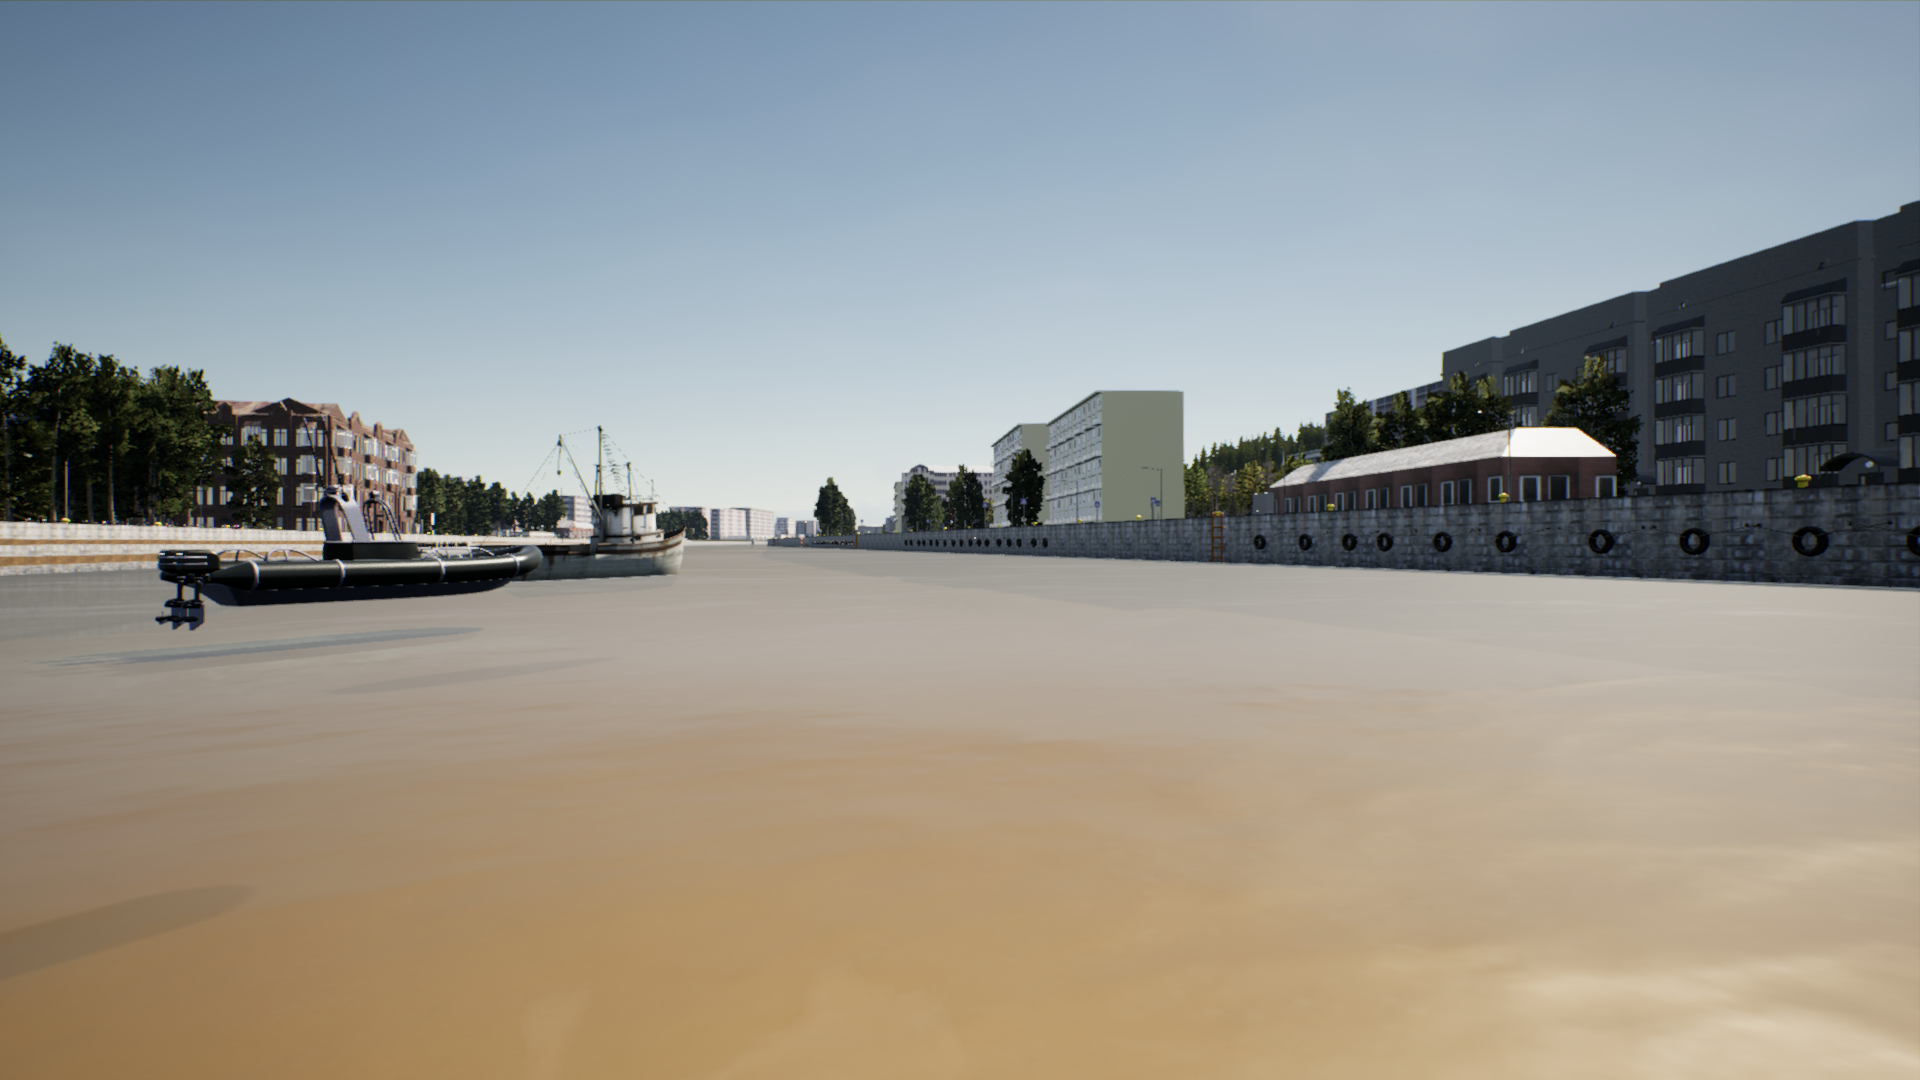
Towards Integrated Digital-twins: An Application Framework for Autonomous Maritime Surface Vessel Development
MDPI Journal of Marine Science and Engineering, 2022
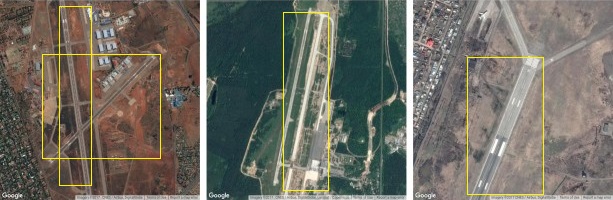
QuantYOLO: A High-Throughput and Power-Efficient Object Detection Network
Digital Image Computing: Techniques and Applications (DICTA), 2021
Patents
Load Handling Controller, Method and Computer Program Product
Hiab AB — EP4596321A1, filed Dec 2024, published Aug 2025
Load Handling System, Method and Computer Program Product
Hiab AB — EP4597249A1, filed Dec 2024, published Aug 2025
Education
-
Aalto University, FinlandPhD in Electrical Engineering and Automation, advised by Prof. Joni PajarinenMay 2025 – Present
-
Åbo Akademi University & University of the Balearic IslandsErasmus Mundus Joint Master's, Engineering of Data-intensive Intelligent Software Systems (EDISS)Sep 2021 – Oct 2023
-
National University of Sciences and Technology (NUST), PakistanBS in Electrical EngineeringSep 2016 – Oct 2020
-
Western Carolina University, USAExchange studies, Global Undergraduate Exchange ProgramJan 2019 – May 2019
Experience
-
Hiab, FinlandRobotic Software Developer — autonomous load handling and human-robot collaborationAug 2023 – May 2025
-
Nokia Bell Labs, FinlandGraduate Research Fellow — hierarchical RL for whole-body mobile manipulationFeb 2023 – Jul 2023
-
Nokia Bell Labs, FinlandResearch Intern — RL vs. classical local planners for mobile robot navigationMay 2022 – Oct 2022
-
Eindhoven University of Technology, NetherlandsResearch Intern — Soft Tissue Biomechanics & Tissue EngineeringJan 2022 – May 2022
-
Åbo Akademi University, FinlandResearch Assistant — Åboat autonomous vessel projectSep 2021 – May 2022
-
Teradata GDC, PakistanAssociate Data ScientistOct 2020 – Jul 2021
-
National Center of Artificial Intelligence, PakistanResearch Assistant — TUKL-NUST LabJun 2018 – Jun 2020
-
Technical University of Kaiserslautern, GermanyResearch Intern — EMS LabJun 2019 – Aug 2019
Awards
- BMoE Grant — Aalto Inventors, Fall 2026
- Unite! Grant — Unite! Research School 2026
- Fully-funded Scholarship — The Cornell, Maryland, Max Planck Pre-doctoral Research School 2024
- Top intern (20 selected out of 275) — Nokia Bell Labs Global Intern Programme 2022
- Erasmus Mundus Joint Master's Scholarship 2021–2023 — EU Commission
- Global Undergraduate Exchange Program Scholarship — US Department of State
- NUST Merit Scholarship — National University of Sciences and Technology
- Silver Medal — District High School Examination (HSE)
Talks & Presentations
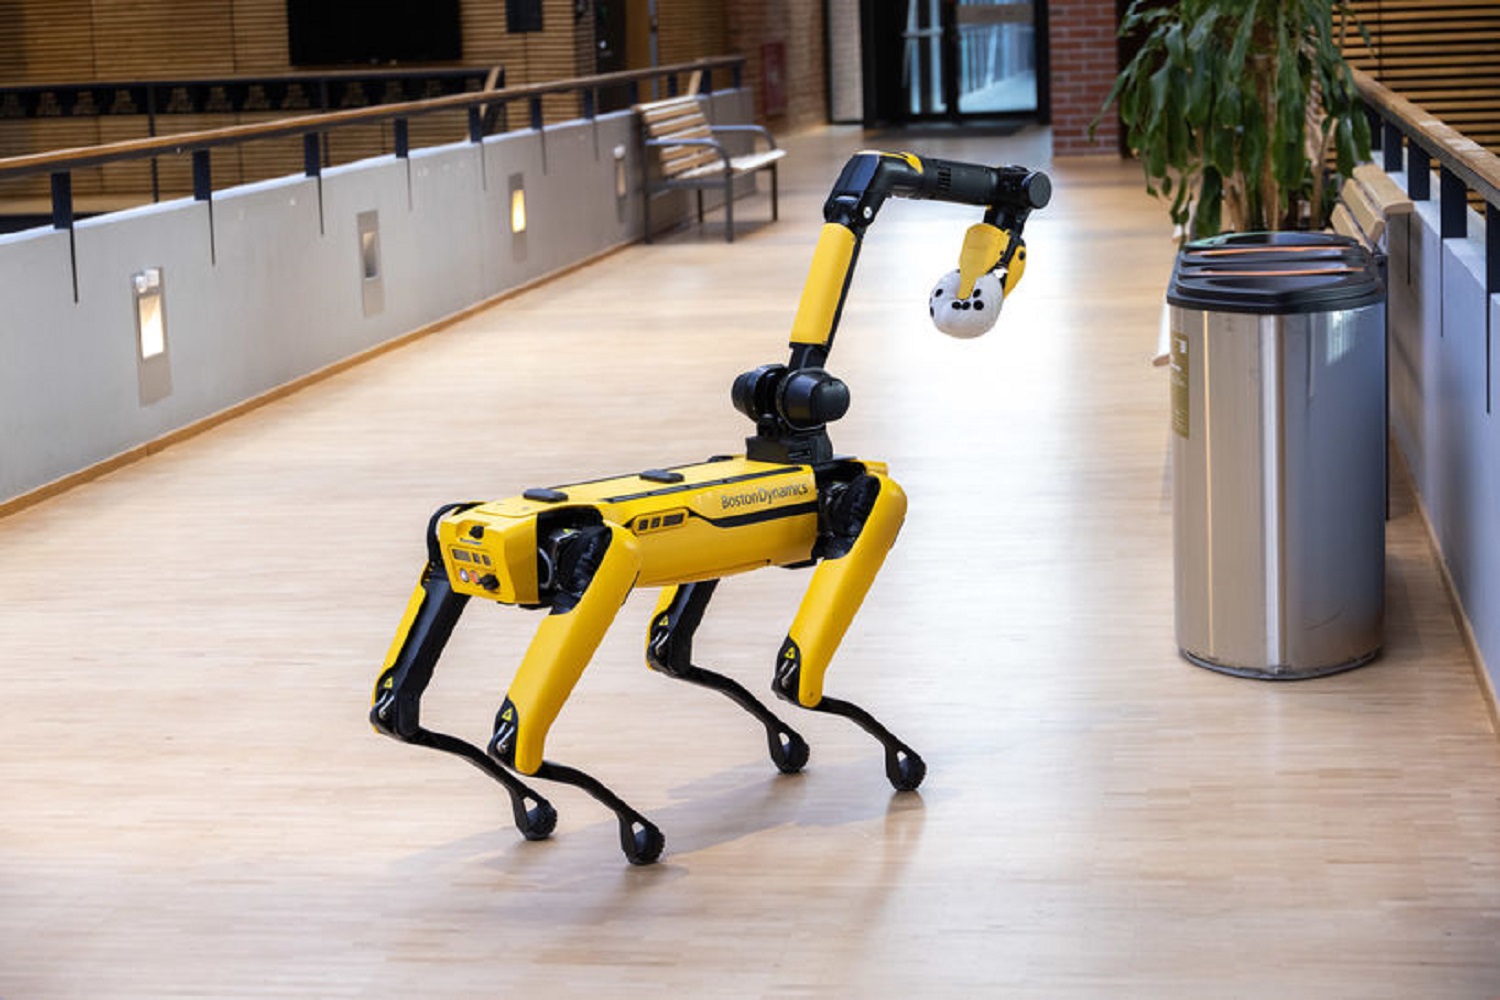 "Spot the Robot Dog" demo — Shaking up Tech, Aalto University (January 2026)